Description
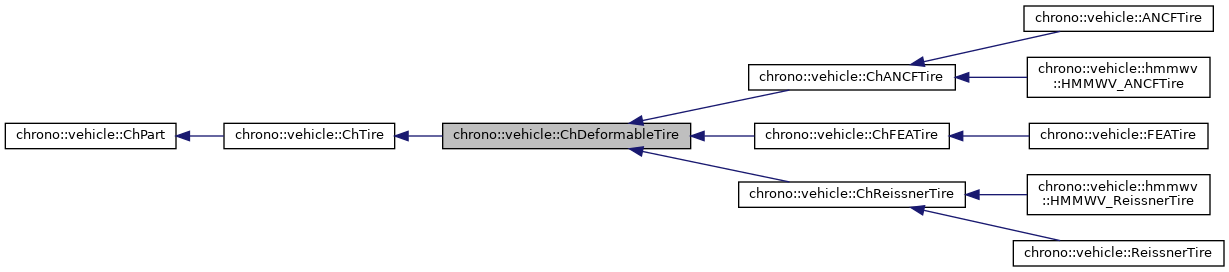
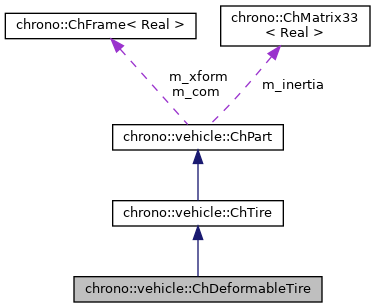
Base class for a deformable tire model.
A deformable tire is modeled with nodes that carry their own state, either as an FEA mesh (see ChFEATire) or as a multibody model (see ChMBTire). Interaction with terrain is through a contact surface over the tire nodes.
#include <ChDeformableTire.h>
Public Member Functions | |
| ChDeformableTire (const std::string &name) | |
| Construct a deformable tire with the specified name. | |
| virtual double | GetTireMass () const override final |
| Return the tire mass. | |
| virtual ChVector3d | GetTireInertia () const override final |
| Return the tire moments of inertia (in the tire centroidal frame). | |
| std::shared_ptr< ChContactMaterialSMC > | GetContactMaterial () const |
| Get the tire contact material. More... | |
| void | EnablePressure (bool val) |
| Enable/disable tire pressure (default: true). | |
| bool | IsPressureEnabled () const |
| void | EnableContact (bool val) |
| Enable/disable tire contact (default: true). | |
| bool | IsContactEnabled () const |
| virtual std::shared_ptr< fea::ChContactSurface > | GetContactSurface () const =0 |
| Get the tire contact surface. More... | |
| virtual std::shared_ptr< fea::ChContactSurfaceMesh > | GetSurfaceMesh () const =0 |
| Get a triangle surface mesh over the tire nodes. More... | |
| virtual double | GetRimRadius () const =0 |
| Get the rim radius (inner tire radius). / TODO: consider removing. | |
| virtual void | WriteCheckpoint (ChCheckpoint::Format format, const std::string &filename) const override |
| Checkpoint the state of this tire (its mesh node states and the internal state of its elements). More... | |
| virtual void | ReadCheckpoint (ChCheckpoint::Format format, const std::string &filename) override |
| Initialize this tire from the given checkpoint file. More... | |
| virtual TerrainForce | ReportTireForceLocal (ChTerrain *terrain, ChCoordsys<> &tire_frame) const override |
| Get the tire force and moment expressed in the tire frame. More... | |
 Public Member Functions inherited from chrono::vehicle::ChTire | |
| void | SetStepsize (double val) |
| Set the integration step size for the underlying dynamics (default: 1ms). More... | |
| double | GetStepsize () const |
| Get the current value of the integration step size. | |
| void | SetCollisionType (CollisionType collision_type) |
| Set the collision type for tire-terrain interaction (default: SINGLE_POINT). More... | |
| void | SetContactSurfaceType (ContactSurfaceType type, double dim=0.01, int collision_family=13) |
| Set the contact surface type (default: NODE_CLOUD). More... | |
| void | SetPressure (double pressure) |
| Set the internal tire pressure [Pa] (default: 0). More... | |
| double | GetPressure () const |
| Get the internal tire pressure [Pa]. | |
| virtual double | GetRadius () const =0 |
| Get the tire radius. | |
| virtual double | GetWidth () const =0 |
| Get the tire width. | |
| virtual TerrainForce | ReportTireForce (ChTerrain *terrain) const =0 |
| Report the tire force and moment. More... | |
| double | GetSlipAngle () const |
| Return the tire slip angle calculated based on the current state of the associated wheel body. More... | |
| double | GetLongitudinalSlip () const |
| Return the tire longitudinal slip calculated based on the current state of the associated wheel body. More... | |
| double | GetCamberAngle () const |
| Return the tire camber angle calculated based on the current state of the associated wheel body. More... | |
| virtual double | GetDeflection () const |
| Report the tire deflection. | |
| const std::string & | GetMeshFilename () const |
| Get the name of the Wavefront file with tire visualization mesh. More... | |
| std::shared_ptr< ChWheel > | GetWheel () const |
| Get the associated wheel. More... | |
| virtual void | Synchronize (double time, const ChTerrain &terrain) |
| Update the state of this tire system at the current time. More... | |
| virtual void | Advance (double step) |
| Advance the state of this tire by the specified time step. | |
| Public Member Functions inherited from chrono::vehicle::ChPart | |
| const std::string & | GetName () const |
| Get the name identifier for this subsystem. | |
| void | SetName (const std::string &name) |
| Set the name identifier for this subsystem. | |
| virtual std::string | GetTemplateName () const =0 |
| Get the name of the vehicle subsystem template. | |
| bool | IsInitialized () const |
| Return flag indicating whether or not the part is fully constructed. | |
| virtual uint16_t | GetVehicleTag () const |
| Get the tag of the associated vehicle. More... | |
| int | GetBodyTag () const |
| Get the tag for component bodies. | |
| double | GetMass () const |
| Get the subsystem mass. More... | |
| const ChFrame & | GetCOMFrame () const |
| Get the current subsystem COM frame (relative to and expressed in the subsystem's reference frame). More... | |
| const ChMatrix33 & | GetInertia () const |
| Get the current subsystem inertia (relative to the subsystem COM frame). More... | |
| const ChFrame & | GetTransform () const |
| Get the current subsystem position relative to the global frame. More... | |
| void | SetVisualizationType (VisualizationType vis) |
| Set the visualization mode for this subsystem. | |
| virtual void | AddVisualizationAssets (VisualizationType vis) |
| Add visualization assets to this subsystem, for the specified visualization mode. | |
| virtual void | RemoveVisualizationAssets () |
| Remove all visualization assets from this subsystem. | |
| virtual void | SetOutput (bool state) |
| Enable/disable output for this subsystem. | |
| bool | OutputEnabled () const |
| Return the output state for this subsystem. | |
| virtual void | ExportComponentList (rapidjson::Document &jsonDocument) const |
| Export this subsystem's component list to the specified JSON object. More... | |
| virtual void | SaveCheckpoint (ChCheckpoint &database) const |
| Save states of this subsystem's components to the specified checkpoint database. More... | |
| virtual void | LoadCheckpoint (ChCheckpoint &database) |
| Load states of this subsystem's components from the specified checkpoint database. More... | |
Protected Member Functions | |
| virtual double | GetDefaultPressure () const =0 |
| Return the default tire pressure. | |
| virtual void | CreateContactMaterial ()=0 |
| Create the SMC contact material. | |
| virtual double | GetAddedMass () const override final |
| Get the mass added to the associated spindle body. More... | |
| virtual ChVector3d | GetAddedInertia () const override final |
| Get the inertia added to the associated spindle body. More... | |
| virtual void | Initialize (std::shared_ptr< ChWheel > wheel) override |
| Initialize this tire by associating it to the specified wheel. More... | |
| virtual TerrainForce | GetTireForce () const override final |
| Get the tire force and moment. More... | |
| Protected Member Functions inherited from chrono::vehicle::ChTire | |
| ChTire (const std::string &name) | |
| Construct a tire subsystem with given name. | |
| void | CalculateKinematics (const WheelState &wheel_state, const ChCoordsys<> &tire_frame) |
| Calculate kinematics quantities based on the given state of the associated wheel body. More... | |
| double | GetOffset () const |
| Get offset from spindle center. More... | |
| std::shared_ptr< ChVisualShapeTriangleMesh > | AddVisualizationMesh (const std::string &mesh_file_left, const std::string &mesh_file_right) |
| Add mesh visualization to the body associated with this tire (a wheel spindle body). More... | |
| Protected Member Functions inherited from chrono::vehicle::ChPart | |
| ChPart (const std::string &name) | |
| Construct a vehicle subsystem with the specified name. | |
| virtual void | InitializeInertiaProperties ()=0 |
| Initialize subsystem inertia properties. More... | |
| virtual void | UpdateInertiaProperties ()=0 |
| Update subsystem inertia properties. More... | |
| void | AddMass (double &mass) |
| Add this subsystem's mass. More... | |
| void | AddInertiaProperties (ChVector3d &com, ChMatrix33<> &inertia) |
| Add this subsystem's inertia properties. More... | |
| virtual void | Create (const rapidjson::Document &d) |
| Create a vehicle subsystem from JSON data. More... | |
| virtual void | PopulateComponentList () |
| Populate lists of Chrono physics items in this subsystem. | |
| void | Initialize () |
| Initialize the part (populate components and mark as initialized). More... | |
| const ChAssembly::Components & | GetComponents () const |
| Get reference to the components of the vehicle part. | |
| virtual std::vector< std::shared_ptr< ChBody > > | GetBodyList () const |
| Get the list of bodies. | |
| void | ExportBodyList (rapidjson::Document &jsonDocument, std::vector< std::shared_ptr< ChBody >> bodies) const |
| Export the list of bodies to the specified JSON document. | |
| void | ExportShaftList (rapidjson::Document &jsonDocument, std::vector< std::shared_ptr< ChShaft >> shafts) const |
| Export the list of shafts to the specified JSON document. | |
| void | ExportJointList (rapidjson::Document &jsonDocument, std::vector< std::shared_ptr< ChLink >> joints) const |
| Export the list of joints to the specified JSON document. | |
| void | ExportCouplesList (rapidjson::Document &jsonDocument, std::vector< std::shared_ptr< ChShaftsCouple >> couples) const |
| Export the list of shaft couples to the specified JSON document. | |
| void | ExportShaftBodyConstraintList (rapidjson::Document &jsonDocument, std::vector< std::shared_ptr< ChShaftBodyRotation >> rot_constraints, std::vector< std::shared_ptr< ChShaftBodyTranslation >> trans_constraints) const |
| Export the list of shaft-body constraints to the specified JSON document. | |
| void | ExportMarkerList (rapidjson::Document &jsonDocument, std::vector< std::shared_ptr< ChMarker >> markers) const |
| Export the list of markers to the specified JSON document. | |
| void | ExportLinSpringList (rapidjson::Document &jsonDocument, std::vector< std::shared_ptr< ChLinkTSDA >> springs) const |
| Export the list of translational springs to the specified JSON document. | |
| void | ExportRotSpringList (rapidjson::Document &jsonDocument, std::vector< std::shared_ptr< ChLinkRSDA >> springs) const |
| Export the list of rotational springs to the specified JSON document. | |
| void | ExportBodyLoadList (rapidjson::Document &jsonDocument, std::vector< std::shared_ptr< ChLoadBodyBody >> loads) const |
| Export the list of body-body loads to the specified JSON document. | |
| void | ExportLinMotorList (rapidjson::Document &jsonDocument, std::vector< std::shared_ptr< ChLinkMotorLinear >> loads) const |
| Export the list of linear motors to the specified JSON document. | |
| void | ExportRotMotorList (rapidjson::Document &jsonDocument, std::vector< std::shared_ptr< ChLinkMotorRotation >> loads) const |
| Export the list of rotational motors to the specified JSON document. | |
Protected Attributes | |
| bool | m_pressure_enabled |
| enable internal tire pressure | |
| bool | m_contact_enabled |
| enable tire-terrain contact | |
| std::shared_ptr< ChContactMaterialSMC > | m_contact_mat |
| tire contact material | |
| Protected Attributes inherited from chrono::vehicle::ChTire | |
| std::shared_ptr< ChWheel > | m_wheel |
| associated wheel subsystem | |
| double | m_stepsize |
| tire integration step size (if applicable) | |
| double | m_pressure |
| internal tire pressure | |
| CollisionType | m_collision_type |
| method used for tire-terrain collision | |
| ContactSurfaceType | m_contact_surface_type |
| type of contact surface model (node cloud or mesh) | |
| double | m_contact_surface_dim |
| contact surface dimension (node radius or mesh thickness) | |
| int | m_collision_family |
| collision family for this tire | |
| std::string | m_vis_mesh_file |
| name of OBJ file for visualization of this tire (may be empty) | |
| double | m_slip_angle |
| double | m_longitudinal_slip |
| double | m_camber_angle |
| Protected Attributes inherited from chrono::vehicle::ChPart | |
| std::string | m_name |
| subsystem name | |
| bool | m_output |
| specifies whether or not output is generated for this subsystem | |
| std::shared_ptr< ChPart > | m_parent |
| parent subsystem (empty if parent is vehicle) | |
| double | m_mass |
| subsystem mass | |
| ChMatrix33 | m_inertia |
| inertia tensor (relative to subsystem COM) | |
| ChFrame | m_com |
| COM frame (relative to subsystem reference frame) | |
| ChFrame | m_xform |
| subsystem frame expressed in the global frame | |
| int | m_obj_tag |
| tag for part objects | |
| ChAssembly::Components | m_components |
Additional Inherited Members | |
| Public Types inherited from chrono::vehicle::ChTire | |
| enum | CollisionType { SINGLE_POINT, FOUR_POINTS, ENVELOPE } |
| Collision detection type. More... | |
| enum | ContactSurfaceType { NODE_CLOUD, TRIANGLE_MESH } |
| Contact surface type. More... | |
| Static Public Member Functions inherited from chrono::vehicle::ChTire | |
| static ChVector3d | EstimateInertia (double tire_width, double aspect_ratio, double rim_diameter, double tire_mass, double t_factor=2) |
| Utility function for estimating the tire moments of inertia. More... | |
| static bool | DiscTerrainCollision (CollisionType method, const ChTerrain &terrain, const ChVector3d &C, const ChVector3d &dn, double r, double w, const ChFunctionInterp &area2depth, ChCoordsys<> &contact, double &depth, float &mu) |
| Perform disc-terrain collision detection, using the specified method. More... | |
| static void | ConstructAreaDepthTable (double r, ChFunctionInterp &area2depth) |
| Utility function to construct a lookup table for penetration depth as function of intersection area. More... | |
| static bool | DiscTerrainCollision1pt (const ChTerrain &terrain, const ChVector3d &C, const ChVector3d &dn, double r, ChCoordsys<> &contact, double &depth, float &mu) |
| Perform disc-terrain collision detection. More... | |
| static bool | DiscTerrainCollision4pt (const ChTerrain &terrain, const ChVector3d &C, const ChVector3d &dn, double r, double w, ChCoordsys<> &contact, double &depth, float &mu) |
| Perform disc-terrain collision detection considering the curvature of the road surface. More... | |
| static bool | DiscTerrainCollisionEnvelope (const ChTerrain &terrain, const ChVector3d &C, const ChVector3d &dn, double r, double w, const ChFunctionInterp &area2depth, ChCoordsys<> &contact, double &depth, float &mu) |
| Collision algorithm based on a paper of J. More... | |
| Static Public Member Functions inherited from chrono::vehicle::ChPart | |
| static ChMatrix33 | TransformInertiaMatrix (const ChVector3d &moments, const ChVector3d &products, const ChMatrix33<> &vehicle_rot, const ChMatrix33<> &body_rot) |
| Utility function for transforming inertia tensors between centroidal frames. More... | |
| Static Protected Member Functions inherited from chrono::vehicle::ChPart | |
| static void | RemoveVisualizationAssets (std::shared_ptr< ChPhysicsItem > item) |
| Erase all visual shapes from the visual model associated with the specified physics item (if any). | |
| static void | RemoveVisualizationAsset (std::shared_ptr< ChPhysicsItem > item, std::shared_ptr< ChVisualShape > shape) |
| Erase the given shape from the visual model associated with the specified physics item (if any). | |
Member Function Documentation
◆ GetAddedInertia()
|
inlinefinaloverrideprotectedvirtual |
Get the inertia added to the associated spindle body.
Certain tires (e.g., those FEA-based) have their own physical representation and hence do not add mass and inertia to the spindle body. All others increment the spindle body moments of inertia by the amount reported by this function.
Implements chrono::vehicle::ChTire.
◆ GetAddedMass()
|
inlinefinaloverrideprotectedvirtual |
Get the mass added to the associated spindle body.
Certain tires (e.g., those FEA-based) have their own physical representation and hence do not add mass and inertia to the spindle body. All others increment the spindle body mass by the amount reported by this function.
Implements chrono::vehicle::ChTire.
◆ GetContactMaterial()
|
inline |
Get the tire contact material.
Note that this is not set until after tire initialization.
◆ GetContactSurface()
|
pure virtual |
Get the tire contact surface.
If contact is not enabled or the tire is not initialized, an empty shared pointer is returned.
Implemented in chrono::vehicle::ChFEATire.
◆ GetSurfaceMesh()
|
pure virtual |
Get a triangle surface mesh over the tire nodes.
This surface is used for interaction with terrain models that require a triangulated tire surface (e.g., CRM terrain). If the tire contact surface is a triangle mesh, it is returned. Otherwise (node cloud contact surface or contact disabled), a triangle surface mesh is created on the first call; this surface is not used for collision. The face normals point outward from the tire (as assumed by the INWARD BCE pattern for CRM terrain). An empty shared pointer is returned if the tire is not initialized.
Implemented in chrono::vehicle::ChFEATire.
◆ GetTireForce()
|
finaloverrideprotectedvirtual |
Get the tire force and moment.
A ChDeformableTire always returns zero forces and moments since tire forces are implicitly applied to the associated wheel through the tire-wheel connections.
Implements chrono::vehicle::ChTire.
◆ Initialize()
|
overrideprotectedvirtual |
Initialize this tire by associating it to the specified wheel.
A derived class must call this base class implementation first.
Reimplemented from chrono::vehicle::ChTire.
Reimplemented in chrono::vehicle::ChFEATire.
◆ ReadCheckpoint()
|
overridevirtual |
Initialize this tire from the given checkpoint file.
The tire must have been initialized and added to a system built the same way as the one that wrote the checkpoint.
Reimplemented from chrono::vehicle::ChTire.
◆ ReportTireForceLocal()
|
overridevirtual |
Get the tire force and moment expressed in the tire frame.
Currently NOT IMPLEMENTED.
Implements chrono::vehicle::ChTire.
◆ WriteCheckpoint()
|
overridevirtual |
Checkpoint the state of this tire (its mesh node states and the internal state of its elements).
The checkpoint is of type ChCheckpoint::Type::COMPONENT.
Reimplemented from chrono::vehicle::ChTire.
The documentation for this class was generated from the following files:
- /builds/uwsbel/chrono/src/chrono_vehicle/wheeled_vehicle/tire/ChDeformableTire.h
- /builds/uwsbel/chrono/src/chrono_vehicle/wheeled_vehicle/tire/ChDeformableTire.cpp