Description
Parser for YAML specification files for Chrono::Vehicle single-wheel test rig simulations (ChWheelTestRig).
A WHEEL_RIG simulation specification file references a rig mechanism file (wheel assembly, rig properties, and MBS solver) and a terrain file (terrain type, patch, parameters, and, for CRM terrain, the SPH solver), and specifies the test scenario and the wheel-terrain coupling settings. The wheel assembly is either a Chrono::Vehicle wheel, tire, and (optional) suspension specified through JSON files (VEHICLE model type), or a custom wheel assembly provided by the application (CUSTOM model type) through a factory registered with RegisterWheelAssembly.
#include <ChParserWheelRigYAML.h>
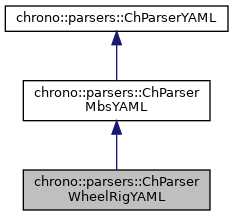
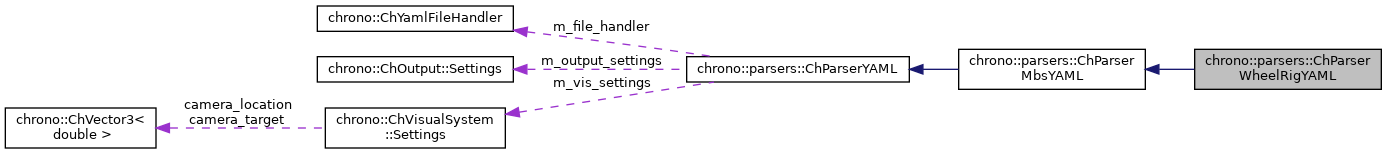
Public Types | |
| using | WheelAssemblyFactory = std::function< std::shared_ptr< vehicle::ChWheelTestRig::WheelAssembly >(ChSystem &sys, const YAML::Node ¶meters)> |
| Factory for a custom wheel assembly. More... | |
 Public Types inherited from chrono::parsers::ChParserYAML | |
| enum | YamlFileType { MBS, SPH, TDPF, FSI, VEHICLE, WHEEL_RIG, CUSTOM } |
Type of a Chrono YAML specification file, as declared by its type key. More... | |
Public Member Functions | |
| ChParserWheelRigYAML (const std::string &yaml_filename, bool verbose=false) | |
| void | RegisterWheelAssembly (const std::string &name, WheelAssemblyFactory factory) |
| Register a factory for custom wheel assemblies with the given name. More... | |
| bool | IsCustomAssembly () const |
| Return true if the rig model specifies a custom wheel assembly. | |
| const std::string & | GetAssemblyName () const |
| Return the name of the custom wheel assembly (empty for a VEHICLE model type). | |
| std::string | GetDataFile (const std::string &filename) const |
| Return the full path of a data file specified relative to the data path of the rig model specification. More... | |
| virtual void | LoadFile (const std::string &yaml_filename) override |
| Load the specified WHEEL_RIG simulation specification file (and the rig and terrain files it references). | |
| std::shared_ptr< vehicle::ChWheelTestRig > | CreateRig (ChSystem &sys) |
| Create the single-wheel test rig in the given system from the cached specification, then initialize it. More... | |
| std::shared_ptr< vehicle::ChWheelTestRig > | GetRig () const |
| Return the test rig (null if not yet created). | |
| vehicle::ChWheelTestRig::TerrainType | GetTerrainType () const |
| Return the terrain type. | |
| double | GetRigStep () const |
| Return the rig step, i.e., the interval for each call to ChWheelTestRig::Advance. More... | |
| bool | StopAtPatchEnd () const |
| Return true if the simulation should end when the wheel reaches the end of the terrain patch. More... | |
| virtual bool | OutputEnabled () const override |
| Return true if generating output, i.e., writing an output database or recording data for plots. | |
| bool | PlotsEnabled () const |
Return true if plots were requested (in the plots section of the simulation specification). | |
| virtual void | WriteOutput (int frame, double time) override |
| Write the rig output channels (see ChWheelTestRig::GetOutputChannels) at the current time and record them for plotting (if plots were requested). More... | |
| void | GeneratePlots () |
| Generate the requested plots from the data recorded during the simulation. More... | |
| const ChVector3d & | GetCameraOffset () const |
| Return the camera location relative to the wheel hub position. | |
| const ChVector3d & | GetCameraTargetOffset () const |
| Return the camera look-at point relative to the wheel hub position. | |
| Public Member Functions inherited from chrono::parsers::ChParserMbsYAML | |
| ChParserMbsYAML (bool verbose=false) | |
| ChParserMbsYAML (const std::string &yaml_filename, bool verbose=false) | |
| bool | HasSolverData () const |
| Return true if a YAML solver file has been loaded. | |
| bool | HasModelData () const |
| Return true if a YAML model file has been loaded. | |
| virtual void | LoadSimData (const YAML::Node &yaml) override |
| Load the simulation, output, and visualization settings from the specified YAML node. | |
| virtual void | LoadModelData (const YAML::Node &yaml) |
| Load the MBS model from the specified YAML node. | |
| virtual void | LoadSolverData (const YAML::Node &yaml) |
| Load the solver parameters from the specified YAML node. | |
| std::shared_ptr< ChSystem > | CreateSystem () |
| Create and return a Chrono system configured from cached simulation parameters. More... | |
| void | SetSimulationParameters (ChSystem &sys) |
| Set solver and integrator settings from cached values. More... | |
| double | GetTimestep () const |
| double | GetEndtime () const |
| bool | EnforceRealtime () const |
| const ChVector3d & | GetGravitationalAcceleration () const |
| VisualizationType | GetVisualizationType () const |
| int | Populate (ChSystem &sys, const ChFramed &model_frame=ChFramed(), const std::string &model_prefix="") |
| Populate the given system with the cached Chrono components. More... | |
| void | Depopulate (ChSystem &sys, int instance_index) |
| Remove from the specified system the Chrono objects from the specified instance. | |
| int | GetNumInstances () const |
| Return the number of instances created from the YAML model file. | |
| std::shared_ptr< ChBodyAuxRef > | FindBodyByName (const std::string &name) const |
| Find and return the body with specified name, in the current model instance. | |
| std::shared_ptr< ChBodyAuxRef > | FindBodyByName (const std::string &name, int model_instance) const |
| Find and return the body with specified name, in the given model instance. | |
| std::vector< std::shared_ptr< ChBodyAuxRef > > | FindBodiesByName (const std::string &name) const |
| Find and return bodies with given base name from all model instances. | |
| std::shared_ptr< ChLinkMotor > | FindMotorByName (const std::string &name) const |
| Find and return the motor with specified name, in the current model instance. | |
| std::shared_ptr< ChLinkMotor > | FindMotorByName (const std::string &name, int model_instance) const |
| Find and return the motor with specified name, in the given model instance. | |
| std::vector< std::shared_ptr< ChLinkMotor > > | FindMotorsByName (const std::string &name) const |
| Find and return motors with given base name from all model instances. | |
| void | AttachLoadController (std::shared_ptr< ChLoadController > controller, const std::string &name, int model_instance) |
| Attach the external controller for the load controller with given name. More... | |
| void | AttachMotorController (std::shared_ptr< ChMotorController > controller, const std::string &name, int model_instance) |
| Attach the external controller for the motor controller with given name. More... | |
| void | DoStepDynamics () |
| Advance dynamics of the multibody system. More... | |
| void | ApplyLoadControllerLoads (const LoadControllerLoads &controller_loads) |
| Apply loads generated by the load controllers in the given list. More... | |
| void | ApplyMotorControllerActuations (const MotorControllerActuations &controller_loads) |
| Apply actuations generated by the motor controllers in the given list. More... | |
| const ChAssembly::Components & | GetOutputComponents () const |
| Get the model components included in output (from all model instances populated so far). | |
| Public Member Functions inherited from chrono::parsers::ChParserYAML | |
| void | SetVerbose (bool verbose) |
| Set verbose terminal output (default: false). | |
| virtual void | SetOutputDir (const std::string &out_dir) |
| Set root output directory (default: "."). More... | |
| const std::string & | GetName () const |
| Return the name of the YAML model. | |
| const ChOutput::Settings & | GetOutputSettings () const |
| Return all output settings. | |
| ChOutput::Format | GetOutputFormat () const |
| Return the output type. | |
| ChOutput::Mode | GetOutputMode () const |
| Return the output mode. | |
| virtual double | GetOutputFPS () const |
| Return the output frequency. | |
| virtual bool | VisualizationEnabled () const |
| Return true if visualization is enabled. | |
| const ChVisualSystem::Settings & | GetVisualizationSettings () const |
| Return all visualization settings. | |
| double | GetRenderFPS () const |
| CameraVerticalDir | GetCameraVerticalDir () const |
| const ChVector3d & | GetCameraLocation () const |
| const ChVector3d & | GetCameraTarget () const |
| bool | EnableShadows () const |
| bool | WriteImages () const |
| const std::string & | GetImageDir () const |
| virtual void | Output (double time) |
| Generate output at the current frame. More... | |
| virtual bool | Render (ChVisualSystem &vis, double time) |
| Render the current frame using the specified visual system if run-time visualization is available and enabled. More... | |
Additional Inherited Members | |
| Static Public Member Functions inherited from chrono::parsers::ChParserYAML | |
| static YamlFileType | ReadYamlFileType (const std::string &yaml_filename) |
| Peek in the specified YAML file and read the declared file type. More... | |
| Static Protected Member Functions inherited from chrono::parsers::ChParserYAML | |
| static YamlFileType | ReadYamlFileType (const YAML::Node &a) |
| Read the YAML file type from the given node. More... | |
| Protected Attributes inherited from chrono::parsers::ChParserYAML | |
| std::string | m_name |
| name of the YAML model | |
| bool | m_verbose |
| verbose terminal output (default: false) | |
| bool | m_use_degrees |
| all angles given in degrees (default: true) | |
| ChVisualSystem::Settings | m_vis_settings |
| visualization settings | |
| ChOutput::Settings | m_output_settings |
| output settings | |
| std::string | m_output_dir |
| root output directory | |
| std::shared_ptr< ChOutput > | m_output_db |
| output database | |
| ChYamlFileHandler | m_file_handler |
| handler for data file paths | |
Member Typedef Documentation
◆ WheelAssemblyFactory
| using chrono::parsers::ChParserWheelRigYAML::WheelAssemblyFactory = std::function<std::shared_ptr<vehicle::ChWheelTestRig::WheelAssembly>(ChSystem& sys, const YAML::Node& parameters)> |
Factory for a custom wheel assembly.
The factory is invoked with the containing system and the parameters node of the rig model specification (an undefined node if no parameters are specified) and must return a wheel assembly constructed in that system.
Member Function Documentation
◆ CreateRig()
| std::shared_ptr< vehicle::ChWheelTestRig > chrono::parsers::ChParserWheelRigYAML::CreateRig | ( | ChSystem & | sys | ) |
Create the single-wheel test rig in the given system from the cached specification, then initialize it.
The system should be created with CreateSystem().
◆ GeneratePlots()
| void chrono::parsers::ChParserWheelRigYAML::GeneratePlots | ( | ) |
Generate the requested plots from the data recorded during the simulation.
For each figure, a Gnuplot script is written to the output directory and executed, producing an image file or an interactive window. This function must be called once, at the end of the simulation; it does nothing if no plots were requested. Plotting requires the Chrono::Postprocess module and Gnuplot.
◆ GetDataFile()
|
inline |
Return the full path of a data file specified relative to the data path of the rig model specification.
This can be used by custom wheel assembly factories to locate their data files.
◆ GetRigStep()
|
inline |
Return the rig step, i.e., the interval for each call to ChWheelTestRig::Advance.
With CRM terrain, this is the FSI coupling step.
◆ RegisterWheelAssembly()
| void chrono::parsers::ChParserWheelRigYAML::RegisterWheelAssembly | ( | const std::string & | name, |
| WheelAssemblyFactory | factory | ||
| ) |
Register a factory for custom wheel assemblies with the given name.
A rig model of CUSTOM type uses the factory registered under the name specified as model.assembly. Factories must be registered before calling CreateRig.
◆ StopAtPatchEnd()
|
inline |
Return true if the simulation should end when the wheel reaches the end of the terrain patch.
See ChWheelTestRig::PatchEndReached.
◆ WriteOutput()
|
overridevirtual |
Write the rig output channels (see ChWheelTestRig::GetOutputChannels) at the current time and record them for plotting (if plots were requested).
The output directory must be set (SetOutputDir) and the rig created (CreateRig) before generating output.
Reimplemented from chrono::parsers::ChParserMbsYAML.
The documentation for this class was generated from the following files:
- /builds/uwsbel/chrono/src/chrono_parsers/yaml/ChParserWheelRigYAML.h
- /builds/uwsbel/chrono/src/chrono_parsers/yaml/ChParserWheelRigYAML.cpp