Classes |
Public Types |
Public Member Functions |
Static Public Member Functions |
Protected Member Functions |
Protected Attributes |
List of all members
chrono::ChOutput Class Referenceabstract
Description
Base class for a Chrono output database.
#include <ChOutput.h>
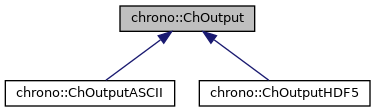
Inheritance diagram for chrono::ChOutput:
Classes | |
| struct | Channel |
| Named scalar output quantity. More... | |
| struct | Settings |
| Output parameters. More... | |
Public Types | |
| enum | Format { Format::ASCII, Format::HDF5, Format::NONE } |
| Output database type. More... | |
| enum | Mode { Mode::FRAMES, Mode::SERIES } |
| Output mode options. More... | |
Public Member Functions | |
| void | Write (int frame, double time, const ChAssembly::Components &components) |
| void | Write (int frame, double time, const std::vector< const ChAssembly::Components * > &components) |
| void | Write (int frame, double time, const std::vector< const ChAssembly::Components * > &components, const std::vector< Channel > &channels) |
| Write output for the given model components and channels. More... | |
Static Public Member Functions | |
| static std::string | GetFormatAsString (Format type) |
| static std::string | GetModeAsString (Mode mode) |
Protected Member Functions | |
| ChOutput (Mode mode) | |
| virtual void | WriteTimeStamp (int frame, double time)=0 |
| virtual void | WriteBodies (const std::vector< std::shared_ptr< ChBody >> &bodies)=0 |
| virtual void | WriteMarkers (const std::vector< std::shared_ptr< ChMarker >> &markers)=0 |
| virtual void | WriteShafts (const std::vector< std::shared_ptr< ChShaft >> &shafts)=0 |
| virtual void | WriteJoints (const std::vector< std::shared_ptr< ChLink >> &joints)=0 |
| virtual void | WriteCouples (const std::vector< std::shared_ptr< ChShaftsCouple >> &couples)=0 |
| virtual void | WriteLinSprings (const std::vector< std::shared_ptr< ChLinkTSDA >> &springs)=0 |
| virtual void | WriteRotSprings (const std::vector< std::shared_ptr< ChLinkRSDA >> &springs)=0 |
| virtual void | WriteBodyBodyLoads (const std::vector< std::shared_ptr< ChLoadBodyBody >> &loads)=0 |
| virtual void | WriteLinMotors (const std::vector< std::shared_ptr< ChLinkMotorLinear >> &motors)=0 |
| virtual void | WriteRotMotors (const std::vector< std::shared_ptr< ChLinkMotorRotation >> &motors)=0 |
| virtual void | WriteChannels (const std::vector< Channel > &channels) |
Protected Attributes | |
| Mode | m_mode |
| output mode | |
| bool | m_buf_allocated |
| buffers allocated? | |
| std::vector< double > | m_time |
| time series | |
| std::vector< BodyBuffers > | m_body_buf |
| body buffers | |
| std::vector< ShaftBuffers > | m_shaft_buf |
| shaft buffers | |
| std::vector< JointBuffers > | m_joint_buf |
| joint buffers | |
| std::vector< TSDABuffers > | m_tsda_buf |
| TSDA buffers. | |
| std::vector< RSDABuffers > | m_rsda_buf |
| RSDA buffers. | |
| std::vector< MeshNodeBuffers > | m_node_buf |
| FEA mesh node buffers. | |
| std::vector< ChannelBuffers > | m_channel_buf |
| channel buffers | |
Member Enumeration Documentation
◆ Format
|
strong |
◆ Mode
|
strong |
Output mode options.
- FRAMES: output is organized in groups for each separate frame; suitable for postprocessing (e.g., rendering).
- SERIES: output is organized by model components, each of them containing time-series for their various output quantities; suitable for plotting results.
| Enumerator | |
|---|---|
| FRAMES | organize output on a frame-by-frame basis |
| SERIES | organize output on component-by-component basis |
Member Function Documentation
◆ Write()
| void chrono::ChOutput::Write | ( | int | frame, |
| double | time, | ||
| const std::vector< const ChAssembly::Components * > & | components, | ||
| const std::vector< Channel > & | channels | ||
| ) |
Write output for the given model components and channels.
The set of channels (names and order) must be the same at every call.
The documentation for this class was generated from the following files:
- /builds/uwsbel/chrono/src/chrono/input_output/ChOutput.h
- /builds/uwsbel/chrono/src/chrono/input_output/ChOutput.cpp