chrono::ChLineCamOscillatingFlat Class Reference
Description
Class to represent the profile of a cam with an oscillating flat follower.
#include <ChLineCam.h>
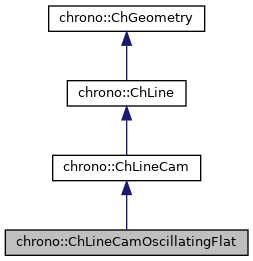
Inheritance diagram for chrono::ChLineCamOscillatingFlat:
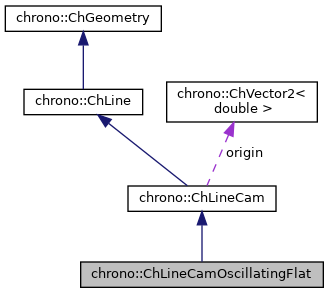
Collaboration diagram for chrono::ChLineCamOscillatingFlat:
Public Member Functions | |
| ChLineCamOscillatingFlat (double follower_arm_offset, double follower_dist, double follower_angle0) | |
| virtual ChLineCamOscillatingFlat * | Clone () const override |
| "Virtual" copy constructor (covariant return type). | |
| void | Initialize (double follower_arm_offset, double follower_dist, double follower_angle0) |
| Initialize data for the oscillating flat follower case. More... | |
| double | GetFollowerDistance () const |
| Get distance between cam and follower origins. | |
| double | GetFollowerStartAngle () const |
| Get initial follower rotation. | |
| ChVector3d | EvaluateCam (double U, double &theta, double &rho) const |
| Return a point on cam profile corresponding to parametric coordinate U in [0, 1]. More... | |
| virtual void | ArchiveOut (ChArchiveOut &archive_out) override |
| Method to allow serialization of transient data to archives. | |
| virtual void | ArchiveIn (ChArchiveIn &archive_in) override |
| Method to allow de-serialization of transient data from archives. | |
 Public Member Functions inherited from chrono::ChLineCam | |
| ChLineCam (const ChLineCam &source) | |
| virtual Type | GetType () const override |
| Get the line class type as an enum. | |
| virtual void | SetClosed (bool state) override |
| Assume the cam as closed by definition. | |
| virtual bool | IsClosed () const override |
| Get if the curve is closed. | |
| TypeFollower | GetFollowerType () const |
| Get follower type. | |
| void | SetOrigin (const ChVector2d &pt) |
| Set position of cam origin in XY plane. | |
| const ChVector2d & | GetOrigin () const |
| Get position of cam origin in XY plane. | |
| double | GetBaseRadius () const |
| Get cam base radius. More... | |
| void | SetPhase (double ang) |
| Set cam phase in [0, 2PI]. | |
| double | GetPhase () const |
| Get cam phase in [0, 2PI]. | |
| void | SetMotionLaw (std::shared_ptr< ChFunction > motion_law) |
| Set motion law produced by cam, as function of angle in [0, 2PI]. | |
| std::shared_ptr< ChFunction > | GetMotionLaw () const |
| Get motion law produced by cam, as function of angle in [0, 2PI]. | |
| void | SetNegative (bool val) |
| If true, create a negative cam. | |
| bool | IsNegative () const |
| Check if the cam is negative (true) or not (false). | |
| void | SetInternal (bool val) |
| If true, create an internal cam. | |
| bool | IsInternal () const |
| Check if cam is internal (true) or not (false). | |
| virtual ChVector3d | Evaluate (double U) const override |
| Return a point on cam profile corresponding to parametric coordinate U in [0, 1]. | |
| double | GetWeight (double U) const |
| Weight evaluation at U in [0, 1]. More... | |
| Public Member Functions inherited from chrono::ChLine | |
| ChLine (const ChLine &source) | |
| virtual ChVector3d | GetTangent (double parU) const |
| Return the tangent unit vector at the parametric coordinate U (in [0,1]). More... | |
| virtual int | GetComplexity () const |
| Get the complexity. | |
| virtual void | SetComplexity (int mc) |
| virtual int | GetManifoldDimension () const override |
| Return dimensionality of this object. More... | |
| bool | FindNearestLinePoint (const ChVector3d &point, double &resU, double approxU, double tol) const |
| Find the parameter resU for the nearest point on curve to "point". | |
| virtual double | Length (int sampling) const |
| Returns curve length. Typical sampling 1..5 (1 already gives correct result with degree1 curves). | |
| virtual ChVector3d | GetEndA () const |
| Return the start point of the line. More... | |
| virtual ChVector3d | GetEndB () const |
| Return the end point of the line. More... | |
| double | CurveCurveDist (const ChLine *compline, int samples) const |
| Return adimensional information on "how much" this curve is similar to another in its overall shape. More... | |
| double | CurveSegmentDist (const ChLine *complinesegm, int samples) const |
| Same as before, but returns "how near" is complinesegm to whatever segment of this line (does not matter the percentual of line). More... | |
| double | CurveCurveDistMax (const ChLine *compline, int samples) const |
| Same as above, but instead of making average of the distances, these functions return the maximum of the distances. | |
| double | CurveSegmentDistMax (const ChLine *complinesegm, int samples) const |
| Public Member Functions inherited from chrono::ChGeometry | |
| ChGeometry (const ChGeometry &other) | |
| virtual ChAABB | GetBoundingBox () const |
| Compute bounding box along the directions of the shape definition frame. More... | |
| void | InflateBoundingBox (ChAABB &bbox) const |
| Enlarge the given existing bounding box with the bounding box of this object. | |
| virtual double | GetBoundingSphereRadius () const |
| Returns the radius of a bounding sphere for this geometry. More... | |
| virtual ChVector3d | Barycenter () const |
| Compute center of mass. | |
| virtual void | Update () |
| Generic update of internal data. | |
Additional Inherited Members | |
| Public Types inherited from chrono::ChLineCam | |
| enum | TypeFollower { TypeFollower::TRANSLATING_INLINE, TypeFollower::TRANSLATING_OFFSET, TypeFollower::TRANSLATING_FLAT, TypeFollower::OSCILLATING_ROLLER, TypeFollower::OSCILLATING_FLAT } |
| Follower types. More... | |
| Public Types inherited from chrono::ChGeometry | |
| enum | Type { NONE, SPHERE, ELLIPSOID, BOX, CYLINDER, TRIANGLE, CAPSULE, CONE, LINE, LINE_ARC, LINE_BEZIER, LINE_CAM, LINE_PATH, LINE_POLY, LINE_SEGMENT, ROUNDED_BOX, ROUNDED_CYLINDER, TRIANGLEMESH, TRIANGLEMESH_CONNECTED, TRIANGLEMESH_SOUP } |
| Enumeration of geometric object types. | |
| Protected Member Functions inherited from chrono::ChLineCam | |
| ChVector3d | CalcProfilePoint (double r, double phi) const |
| Protected Attributes inherited from chrono::ChLineCam | |
| TypeFollower | type = TypeFollower::TRANSLATING_INLINE |
| type of cam | |
| ChVector2d | origin |
| cam origin in XY plane | |
| std::shared_ptr< ChFunction > | motlaw |
| follower motion law as function of angle in [0, 2PI] | |
| double | phase = 0 |
| cam phase (rotation) in [0, 2PI]; default=0, neutral position | |
| double | Rb = 0 |
| cam base radius | |
| bool | negative = false |
| negative cam: for desmodromic applications (cam is also Y or X mirrored, depending on type) | |
| bool | internal = false |
| follower roller is inside the cam | |
| Protected Attributes inherited from chrono::ChLine | |
| bool | closed |
| int | complexityU |
Member Function Documentation
◆ EvaluateCam()
|
virtual |
Return a point on cam profile corresponding to parametric coordinate U in [0, 1].
Additionally return pressure angle theta and curvature radius rho in U.
Implements chrono::ChLineCam.
◆ Initialize()
| void chrono::ChLineCamOscillatingFlat::Initialize | ( | double | follower_arm_offset, |
| double | follower_dist, | ||
| double | follower_angle0 | ||
| ) |
Initialize data for the oscillating flat follower case.
Provide follower arm offset, cam-follower origins distance, and follower initial phase angle. Autocompute cam base radius.
The documentation for this class was generated from the following files:
- /builds/uwsbel/chrono/src/chrono/geometry/ChLineCam.h
- /builds/uwsbel/chrono/src/chrono/geometry/ChLineCam.cpp